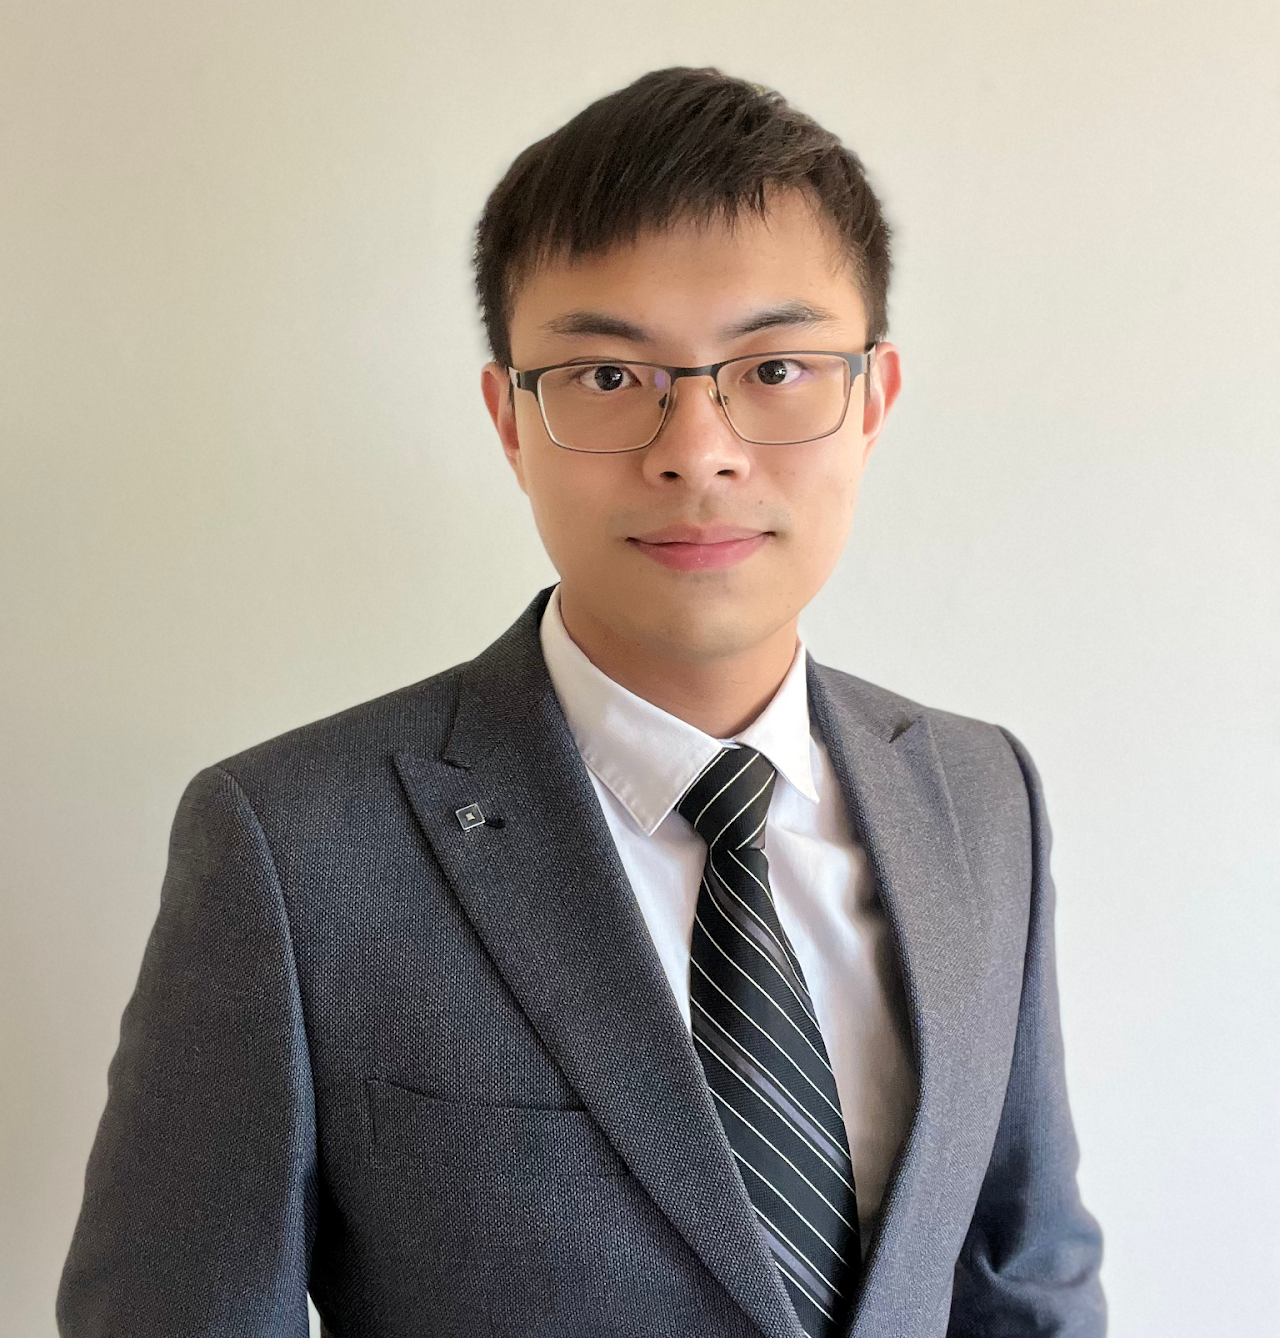
Ph.D., Mechanical Engineering, 2026
Joined Fall 2021
- Ph.D., Mechanical Engineering, Iowa State University, 2026
- M.S., Applied Mechanics, National Taiwan University, 2020
- B.S., Engineering Science and Ocean Engineering, National Taiwan University, 2018
Hsin-Jung completed his Ph.D. in the Department of Mechanical Engineering at Iowa State University, defending in Summer 2026. He joined the Self-aware Complex Systems Laboratory in Fall 2021, where his research focused on machine learning, deep learning, mechatronics, and robotics. His other interests include hiking and photography.
Research interests: Machine learning, deep learning, mechatronics, robotics
Publications with the lab (9)
- Enhancing PPO With Trajectory-Aware Hybrid Policies — IEEE Transactions on Neural Networks and Learning Systems (2026)
- LexiSafe: Offline Safe Reinforcement Learning with Lexicographic Safety-Reward Hierarchy — arXiv (2026)
- Data-driven Kinematic Modeling in Soft Robots: System Identification and Uncertainty Quantification — 5th Modeling, Estimation and Control Conference (MECC 2025) (2025)
Show all 9
- Find the fruit: Designing a zero-shot sim2real deep rl planner for occlusion aware plant manipulation — IEEE International Conference on Robotics and Automation (ICRA 2026), in press (2026)
- Zero-shot Sim-to-Real Transfer for Reinforcement Learning-based Visual Servoing of Soft Continuum Arms — Proceedings of the 7th Annual Learning for Dynamics & Control Conference (L4DC 2025), PMLR 283 (2025)
- In the Mix: A Workshop Merging Computational Chemistry and Electrochemistry Alongside Data Science — Journal of chemical education (2024)
- Persistent monitoring of insect-pests on sticky traps through hierarchical transfer learning and slicing-aided hyper inference — Frontiers in Plant Science (2024)
- GENESIS-RL: GEnerating natural edge-cases with systematic integration of safety considerations and reinforcement learning — 2024 IEEE International Automated Vehicle Validation Conference (IAVVC) (2024)
- Deep Reinforcement Learning for Robotic Control with Multi-Fidelity Models — IFAC-PapersOnLine (2022)
hjy (@) iastate.eduLinkedInGoogle ScholarGitHub